PRECISION / AUTONOMY
Line Follower
Precision autonomous tracking on a timed course.
Design an autonomous robot to follow a marked path. Tune your sensors, master the turns and aim for a clean, fast run.
The challenge
Teach your robot to read the road.
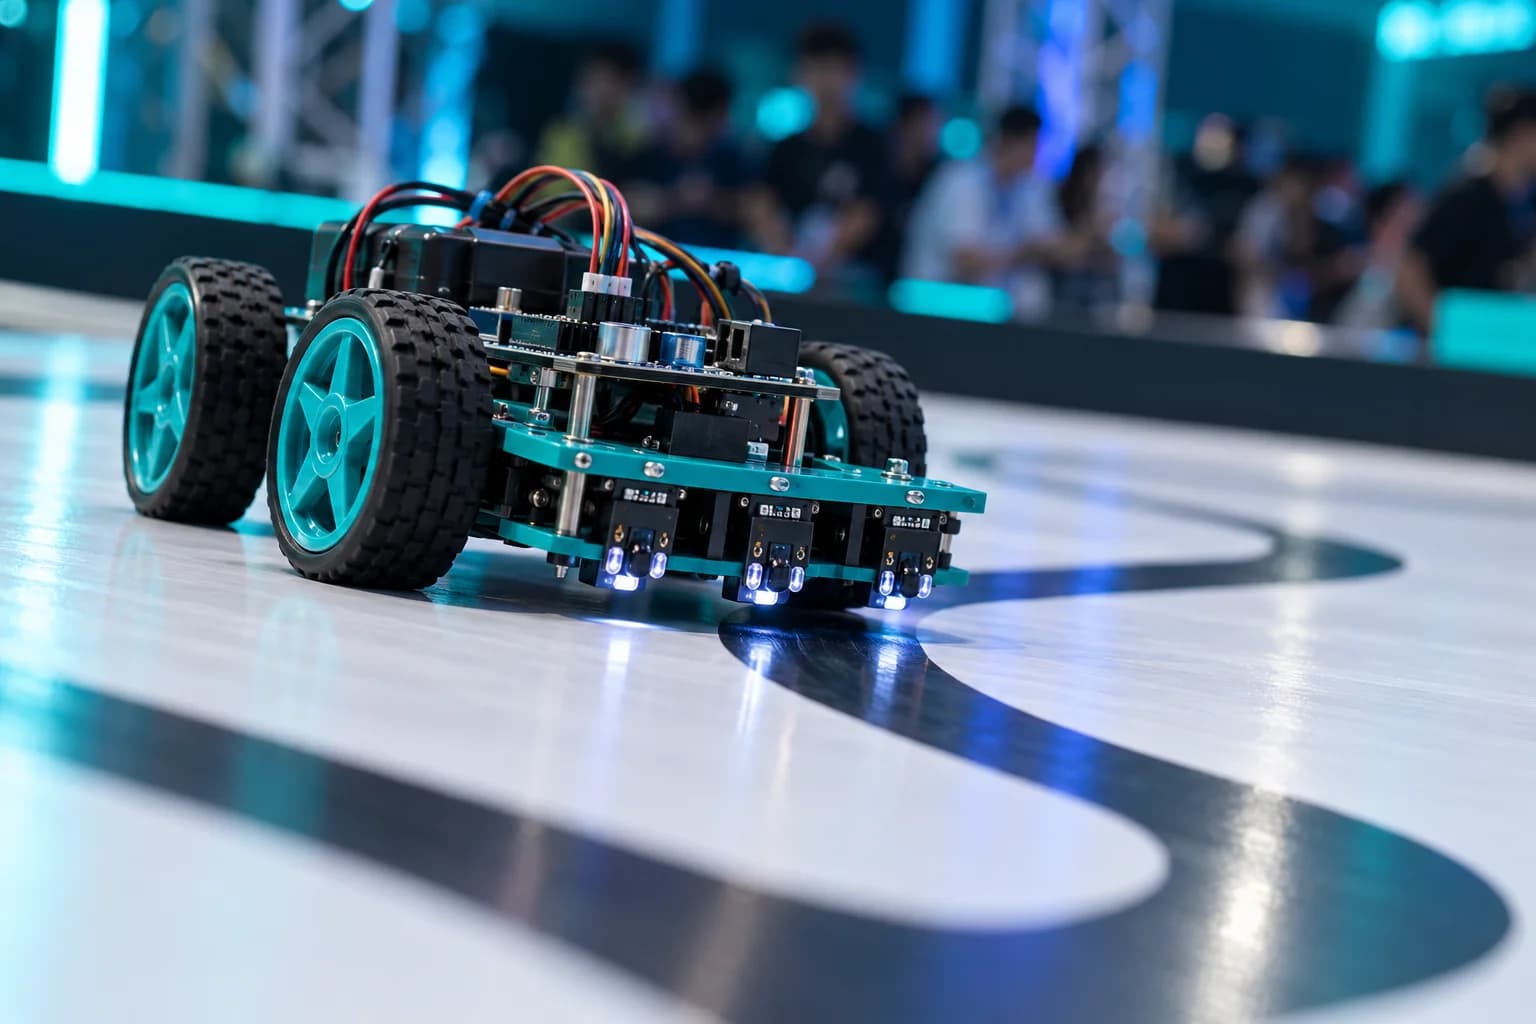
Your autonomous robot must recognise a marked line, follow it through bends and recover its path without a driver. A fast run matters, but consistent sensing, smooth turns and reliable decisions are what get you to the finish. This is an accessible starting point for students exploring feedback control.
Your mission
Detect the line using suitable optical sensors and calibrated thresholds.
Navigate straights and turns while keeping the robot on the route.
Recover from small tracking errors and complete a clean timed attempt.
Skills you will put to work
2027 scoring guidance · SmartTrack
Rules & scoring
Document baseline: up to 180 seconds per run. The final rulebook may change this limit.
How the score determines ranking
Compare completion or mission status first, penalties second, then elapsed time. Within equivalent completion and penalty results, the faster valid run ranks higher.
| Criterion | Calculation / priority |
|---|---|
| Completion / mission status | First ranking priority; the exact status hierarchy is awaiting the final rulebook. |
| Penalties | Second ranking priority; numerical values are awaiting the final rulebook. |
| Elapsed time | Third ranking priority; faster is better after the earlier criteria are applied. |
During your run or match
- Start fully inside the start box, with hands off before the countdown.
- No external control after the start.
- Touching or resetting the robot requires referee permission and must follow the published reset rule.
- The reference field is a matte white base with a nominal 25 mm black line; final arena dimensions are awaiting the rulebook.
Awaiting the final rulebook
The supplied guidance does not define percentage score weightages or a complete weighted-score formula. No percentage weights have been assigned.
- Number of attempts and best-run selection
- Exact start / finish timing definition and completion categories
- Line-loss, contact and reset penalties; restart conditions
- Final track dimensions and tie-break procedure
Prepare for your best run
- Test your sensors under different room lighting and track surfaces.
- Practise gentle and sharp turns; tune speed before increasing it.
- Secure wires, check wheel alignment and carry charged batteries.
- Keep a written log of changes so your team can explain its design.
Before you compete
This page includes the 2027 document baseline. Missing score values, exact penalties and final arena specifications are awaiting the final rulebook. Your robot must pass technical inspection before it enters the arena.